|
Philipp Schröppel I am a PhD candidate in the Computer Vision Group at the University of Freiburg, headed by Thomas Brox. Recently, I did a research visit at the Visual Intelligence & Perception Lab within the Max Planck Institute for Informatics, headed by Jan Eric Lenssen. In recent years, I have worked on 3D computer vision, diffusion-based generative models, and object-centric learning. Currently I am most interested in generative 3D reconstruction, world models, robotics, LLMs, and algorithms that learn compact, composable, abstract representations. Also, I develop and maintain the Robust Multi-view Depth (robustmvd) benchmark and framework. It allows the use and evaluation of depth estimation models with a common interface. |

|
Publications |
|
Diffusion for Out-of-Distribution Detection on Road Scenes and Beyond
Silvio Galesso*, Philipp Schröppel*, Hssan Driss, Thomas Brox (* denotes equal contribution) ECCV, 2024 Paper / Code / ADE-OoD Benchmark / Bibtex We introduce ADE-OoD, a novel benchmark for out-of-distribution (OoD) detection for semantic segmentation on general natural images, and DOoD, a diffusion-based method that detects OoD samples by perturbing them and checking the directional error of the estimated score. |
|
Neural Point Cloud Diffusion for Disentangled 3D Shape and Appearance Generation
Philipp Schröppel, Christopher Wewer, Jan Eric Lenssen, Eddy Ilg, Thomas Brox CVPR, 2024 Paper / Project page / Code / Bibtex We generate 3D shape and appearance of objects via diffusion on neural point clouds (points with a 3D position and a learned feature). As the point positions represent the coarse shape and the features represent the appearance, shape and appearance can be generated separately. |
|
A Benchmark and a Baseline for Robust Multi-view Depth Estimation
Philipp Schröppel, Jan Bechtold, Artemij Amiranashvili, Thomas Brox 3DV, 2022 Paper / Code / Bibtex We introduce a benchmark for robust zero-shot multi-view depth estimation and evaluate many recent models. We present a new model that works more robustly across data from different domains and can serve as a baseline for future evaluations on the benchmark. |
|
SF2SE3: Clustering Scene Flow into SE (3)-Motions via Proposal and Selection
Leonhard Sommer, Philipp Schröppel, Thomas Brox GCPR, 2022 Paper / Code / Bibtex We propose SF2SE3, an approach to estimate a moving object segmentation and corresponding SE(3) motions from optical flow and depth. It works by iteratively sampling motion proposals and selecting the best ones with respect to a maximum coverage formulation. |
|
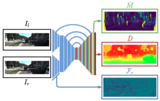
Semi-Supervised Disparity Estimation with Deep Feature Reconstruction
Julia Guerrero-Viu, Sergio Izquierdo, Philipp Schröppel, Thomas Brox CVPR Women in Computer Vision Workshop, 2021 Paper We train a network for disparity estimation in a semi-supervised fashion on labeled synthetic data and unlabeled real data. For supervision on the unlabeled data, we explore a deep feature reconstruction loss, instead of the commonly used photometric loss. |
Academic Activities |
| Research Visits | Visiting Researcher at the Visual Intelligence & Perception Lab within the Max Planck Institute for Informatics, Saarbrücken, 12/2024 – 04/2026 |
| Reviewing |
CVPR 2023, ICCV 2023, IJCV 2024, CVPR 2024, TPAMI 2024, CVPR 2025, NeurIPS 2025
(bold denotes outstanding reviewer) |
| Mentoring | Supervised 7 Master's theses and 4 Master's projects on depth estimation, pose estimation, scene flow estimation, disparity estimation, and 3D object detection |
| Teaching | Served as a teaching assistant for the courses Computer Vision, Statistical Pattern Recognition, and Image Processing |
| Summer Schools | ICVSS 2025 (International Computer Vision Summer School, Sicily) |
|
The template for this website comes from Jon Barron. Thanks! |